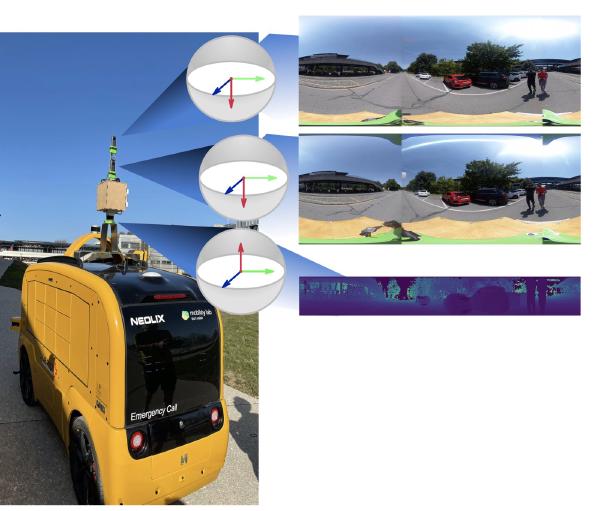
MSc thesis: recorded a new real-world dataset of 17,373 stereo 360° image pairs with LiDAR depth ground truth, and adapted deep stereo networks (PSMNet, 360SD-Net) to work on it without rectification.
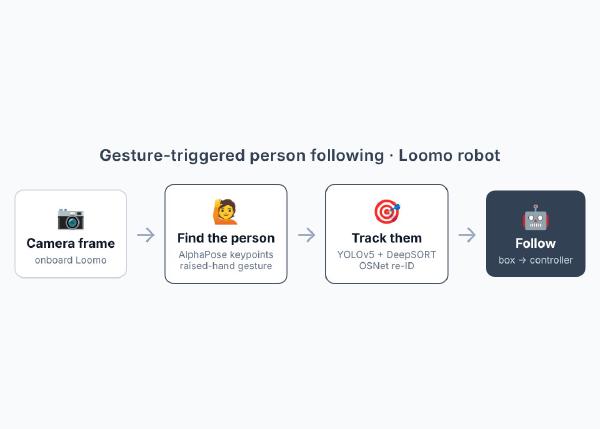
Real-time perception pipeline for EPFL’s human–robot tandem race: a Segway Loomo picks out the person who raises a hand using AlphaPose keypoints, then keeps them locked in with YOLOv5 + DeepSORT while it follows them.
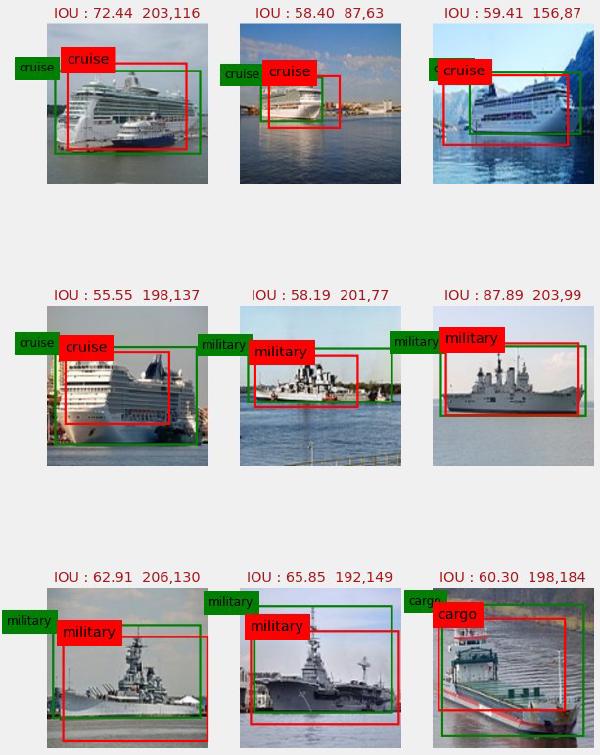
Classify ships into five types (cargo, carrier, cruise, military, tanker) and localise them in the image, on ~6,200 hand-annotated images with bounding boxes. Compares a single multi-output MobileNetV2 against a split Xception + MobileNetV2 pair.