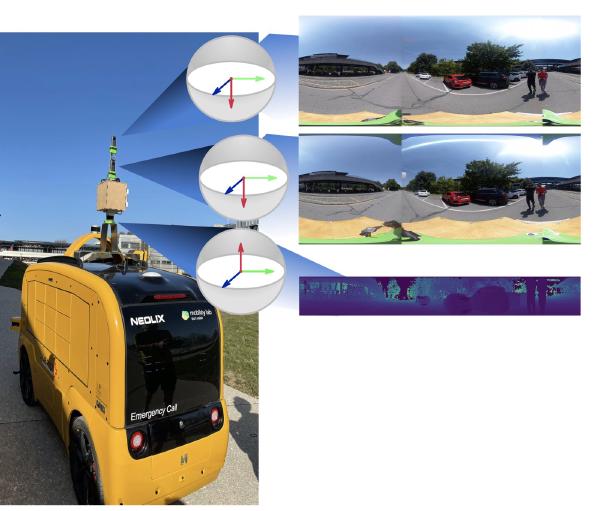
Stereo Depth Estimation on a Real, Unrectified 360° Dataset
MSc thesis: recorded a new real-world dataset of 17,373 stereo 360° image pairs with LiDAR depth ground truth, and adapted deep stereo networks (PSMNet, 360SD-Net) to work on it without rectification.